

Multiple Dynamic Engines
5 physics engines (MuJoCo, Bullet Physics, ODE, Newton and Vortex Dynamics) for fast and customizable dynamics calculations, to simulate real-world physics and object interactions (collision response, grasping, soft bodies, strings, ropes, cloths, etc.).

Forward / Inverse Kinematics
Forward/Inverse kinematics calculations for any type of mechanism (branched, closed, redundant, containing nested loops, etc.). An embeddable version of the IK/FK algorithms is available.

Sensor simulation
Powerful, realistic and exact volumetric proximity sensor simulation: performs an exact minimum distance calculation within a customizable detection volume. Operates on meshes, octrees and point clouds. Simulation of vision sensors with many image processing options, fully customizable and extendable (e.g. via plugin).

Path and Motion Planning
Path planning / motion planning is supported in a very flexible way via the OMPL library wrapped in a plugin for CoppeliaSim.

Powerful APIs
5 Programming Approaches, 7 Languages. Powerful API: Python, Lua, C/C++, Java, JavaScript, MATLAB , Octave. ROS interfaces: publishers, subscribers & service calls. ZeroMQ messaging, WebSockets, and more.

Collision & Distance Calculation
Fast collision checking between any mesh, octree, point cloud, or collection of those. Fast and exact minimum distance calculation between any mesh (convex, concave, open, closed), octree, point cloud, or collection of those.

Vast collection of plugins and add-ons
Plugins for trajectory generation, custom user interfaces, computer vision, computational geometry, importing and exporting to many formats, and more!

Many More Features
Browser-based viewer, multilevel undo/redo, movie recorder, simulation of paint or welding seams, OC trees, point clouds. For a complete description of all the CoppeliaSim features please refer to the User manual
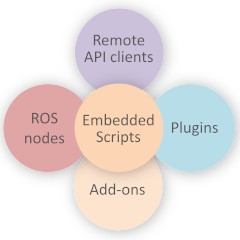
5 Programming Approaches
Simulator and simulations are fully customizable, with 5 programming approaches that are mutually compatible and that can even work hand-in-hand. 6 supported programming languages.
Collision Detection
Fast interference checking between any mesh, OC tree, point cloud, or collection of those.
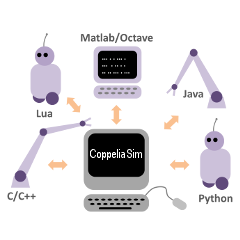
Remote API
Control a simulation or the simulator itself remotely (e.g. from a real robot or another PC)
Dynamics/Physics
5 physics engines (MuJoCo, Bullet Physics, ODE, Vortex and Newton Dynamics) for fast and customizable dynamics calculations, to simulate real-world physics and object interactions (collision response, grasping, etc.)
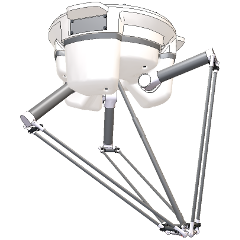
Inverse/Forward Kinematics
Inverse/forward kinematics calculations for any type of mechanism (branched, closed, redundant, containing nested loops, etc.). An embeddable version of the IK/FK algorithms is available (i.e. can run on your robot).
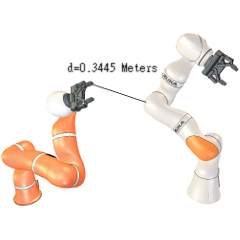
Minimum Distance Calculation
Fast and exact minimum distance calculation between any mesh (convex, concave, open, closed), OC tree, point cloud, or collection of those.
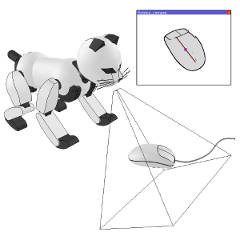
Vision Sensor Simulation
Simulation of vision sensors with many possibilities for image processing, fully customizable and extendable (e.g. via plugin)
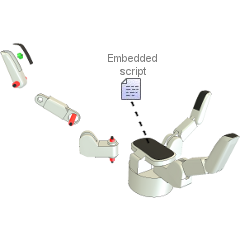
Building Block Concept
Anything - from sensors or actuators, to whole robotic systems - can be built within CoppeliaSim by combining basic objects and linking various functionality via embedded scripts. Every scene object can have its own embedded script!
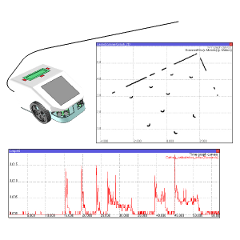
Data Recording and Visualization
A large variety of recordable data streams (including user-defined) can display time-graphs, or can be combined with each other to form x/y-graphs, or 3D curves
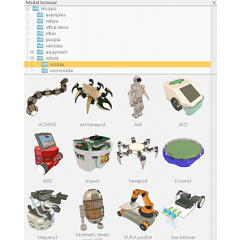
Convenient Model Browser
The integrated model browser supports drag-and-drop operations (also during simulation!) for convenient scene composition. The available model library, updated at each release, can be easily extended by the user
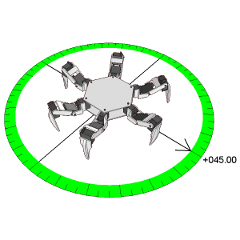
Full Interaction
Full interaction also during simulations: models, together with their associated behavior (i.e. embedded scripts) can be shifted, rotated, copy/pasted, scaled, erased, etc. without having to adjust any code
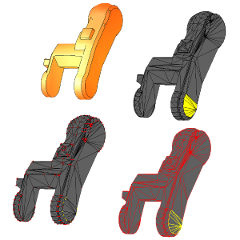
Integrated Edit Modes
Special mesh edit modes are supported (including a semi-automatic primitive shape extraction method, convex decomposition, mesh decimation, etc.)